> For the complete documentation index, see [llms.txt](https://build.yourownrobot.ai/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://build.yourownrobot.ai/5.-mounting-the-arms-1.md).
# 5.1 Mounting the Nero Arms
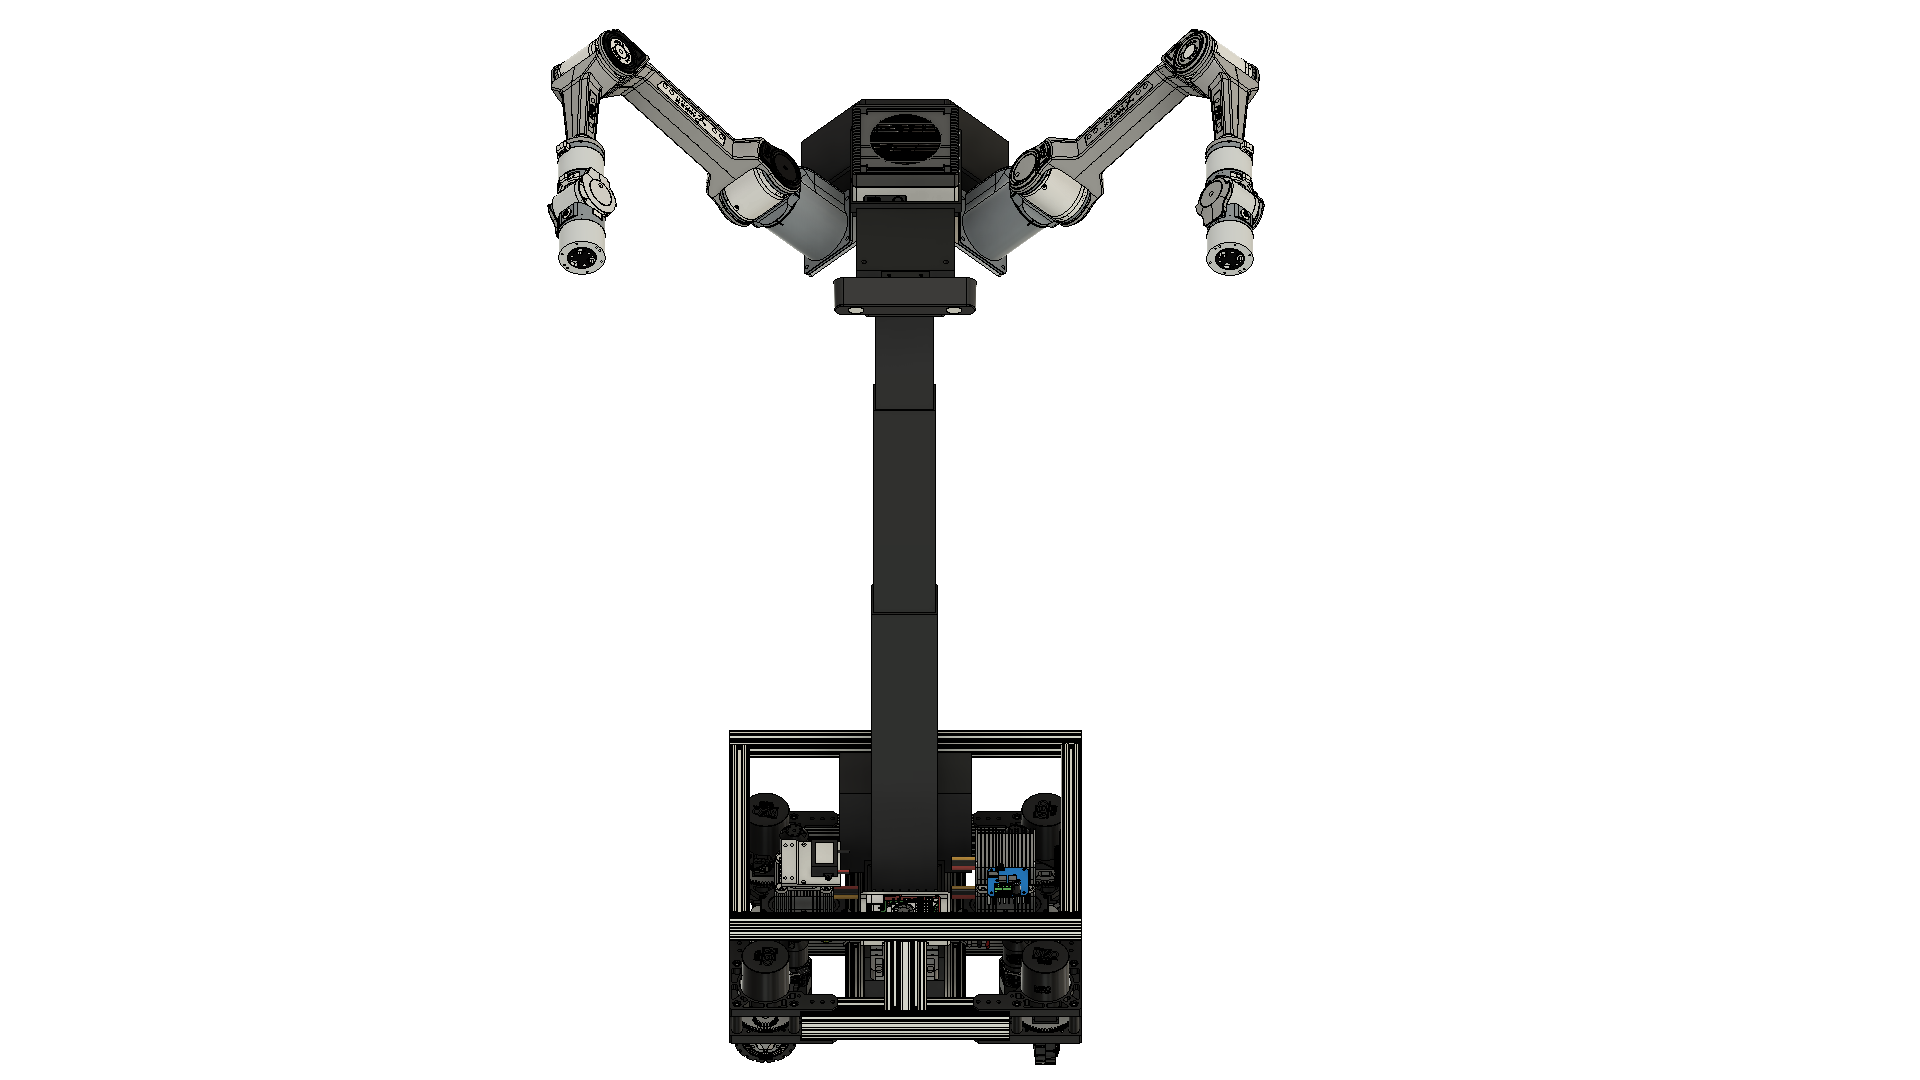
This section covers mounting the Nero arms to the YOR base using the YOR Nero arm attachment plate.
After all the motors are updated and configured correctly, we now move on to mounting the arms on the [Nero Arms attachment plate](https://drive.google.com/file/d/1CYvqHdz5FVxU29ZuSA-94ZRtbvt0eQae/view?usp=sharing).
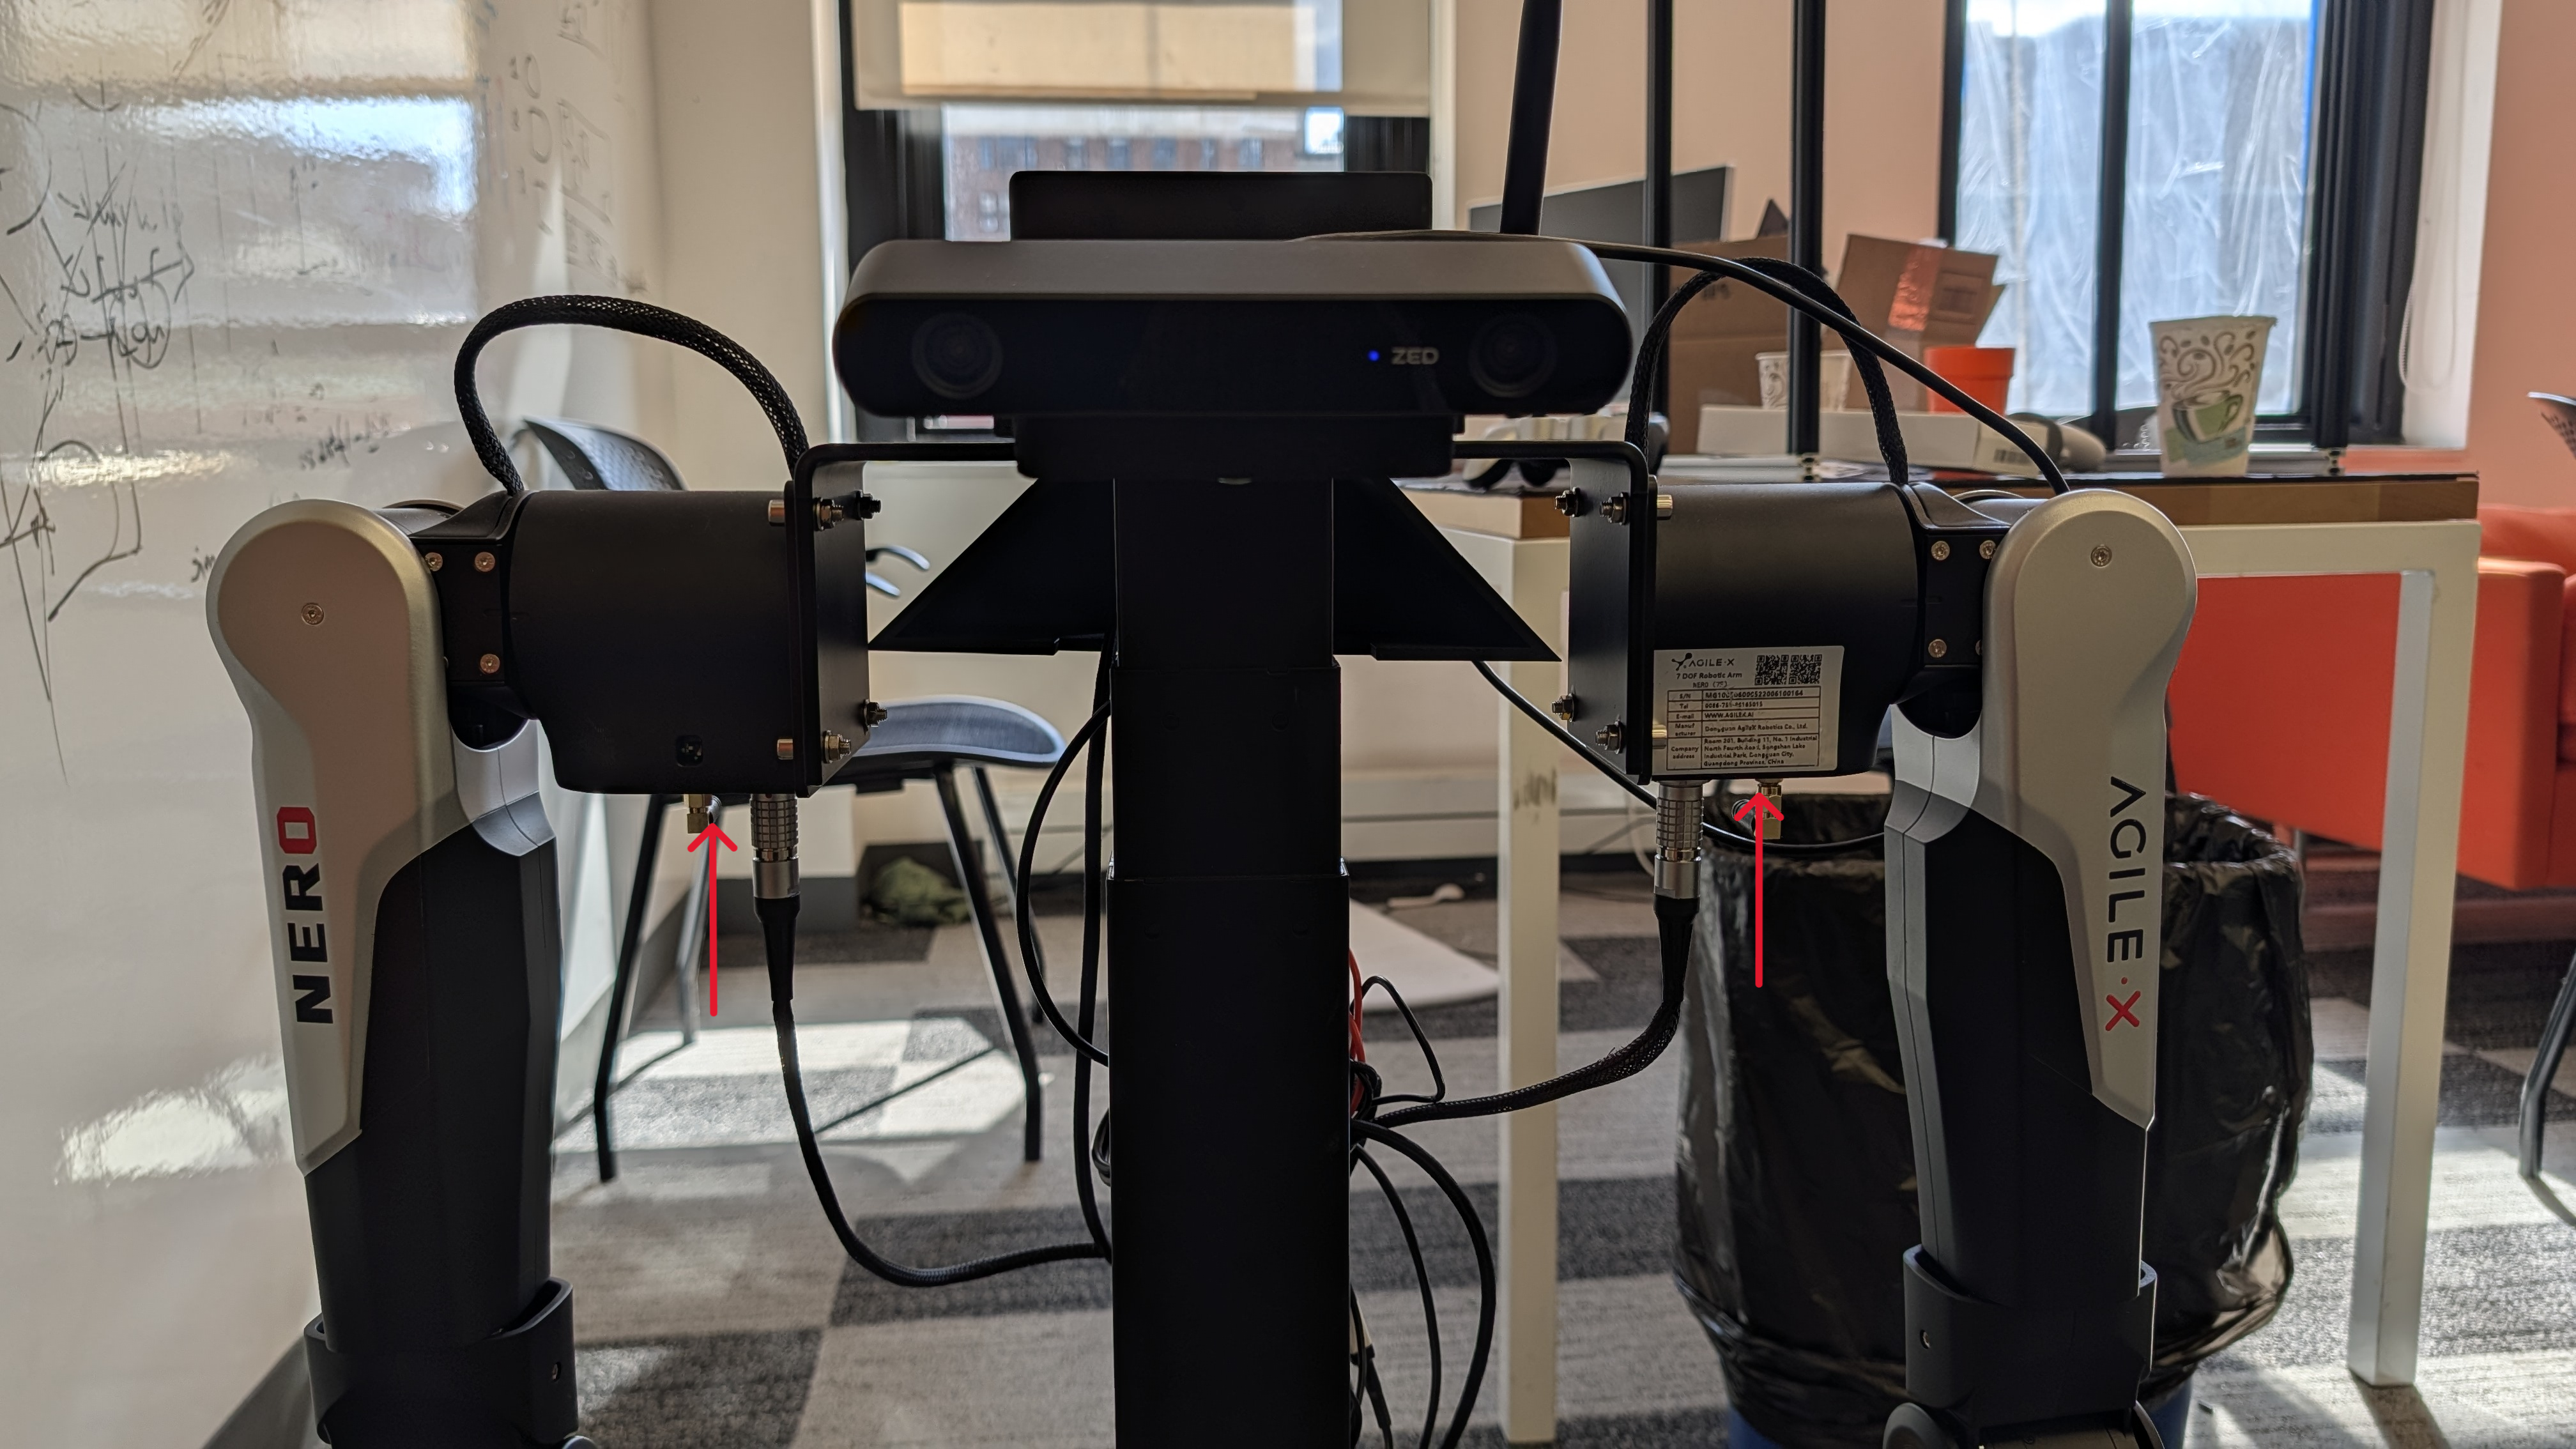
Take the 4.7 mm stainless steel mounting plate and attach the two Nero arms using eight M5 × 25 mm hex bolts and M5 lock nuts. Tighten the fasteners using a ratcheting wrench with an M5 socket and an M5 Allen key.
**Note: Make sure orientation of the arms is exactly as shown in the figure.**
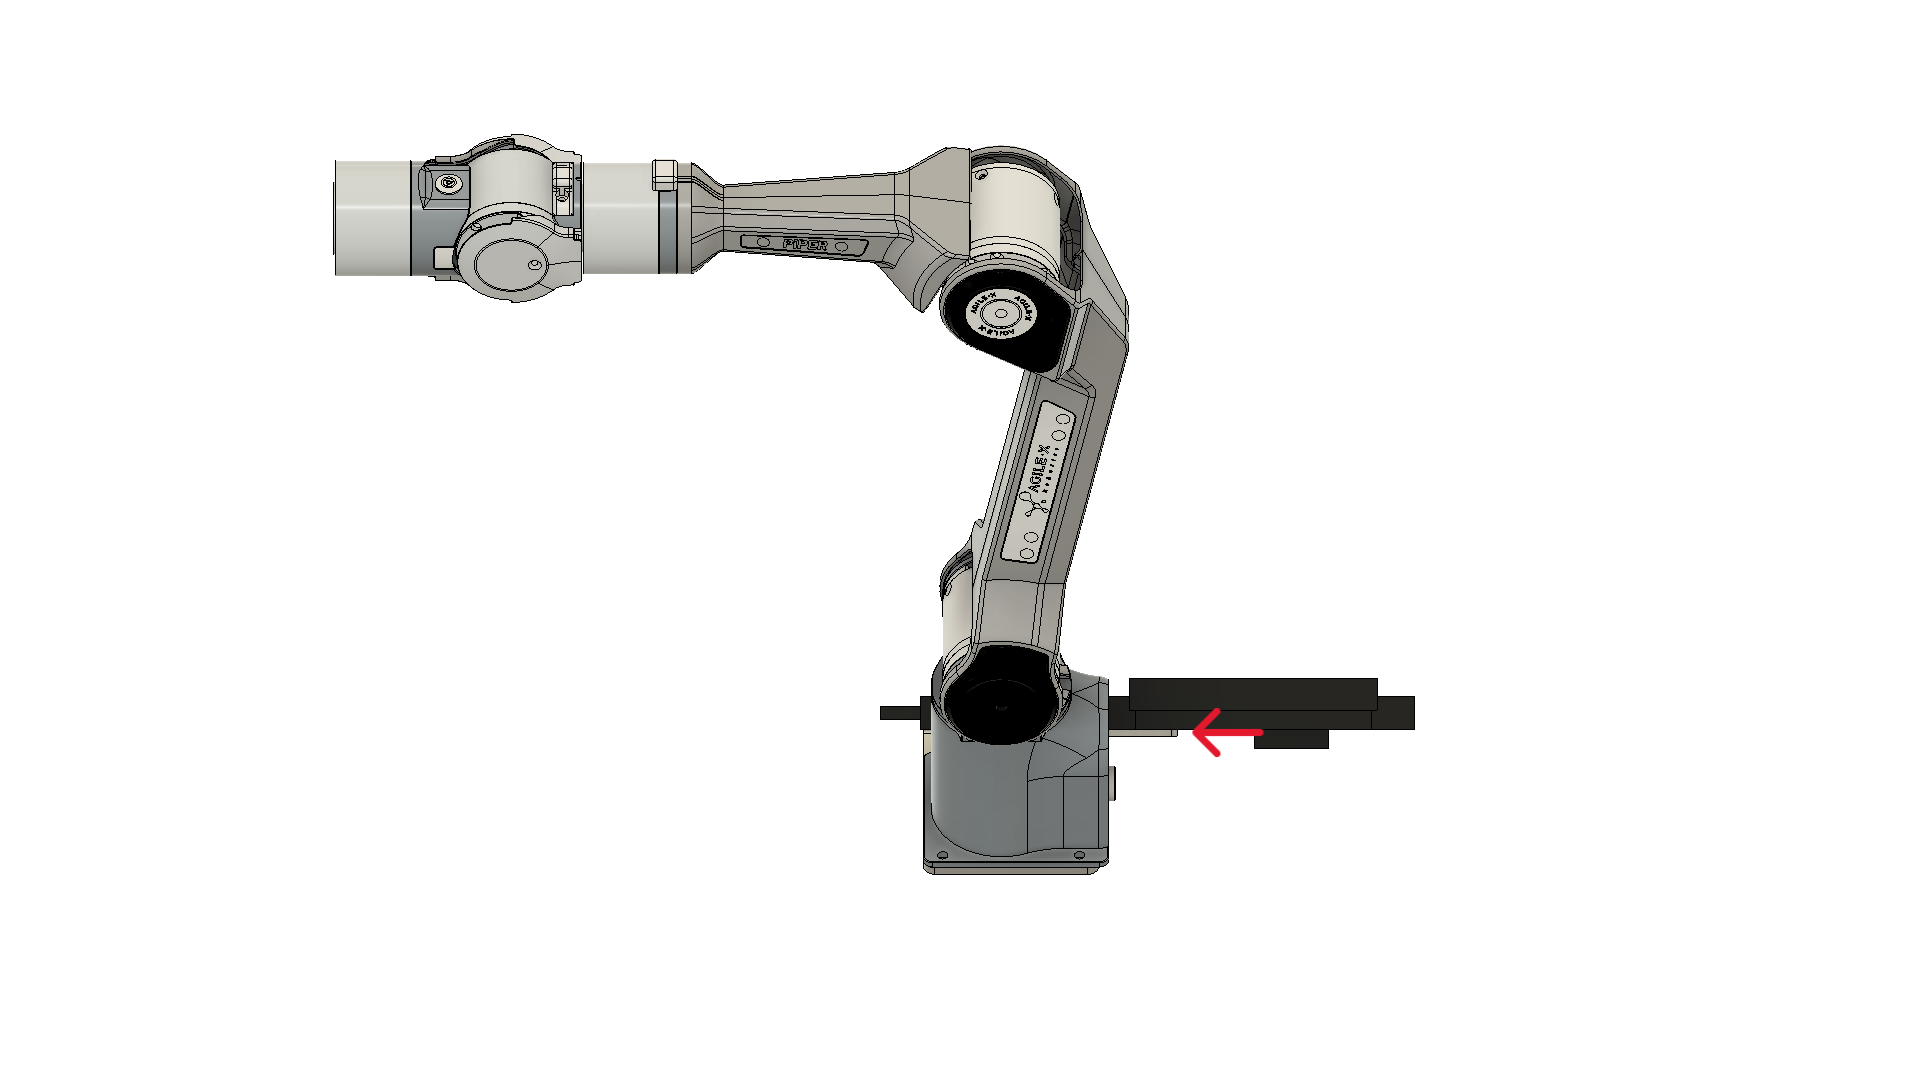
Mount the arms on the plate such that the connectors are facing the floor
**Note: Only the arm orientation differs; all other steps are identical for both the Nero arms and the Piper arms.**
Now attach the Jetson mount to the arm plate by sliding the slot on the Jetson mount into the arm plate.
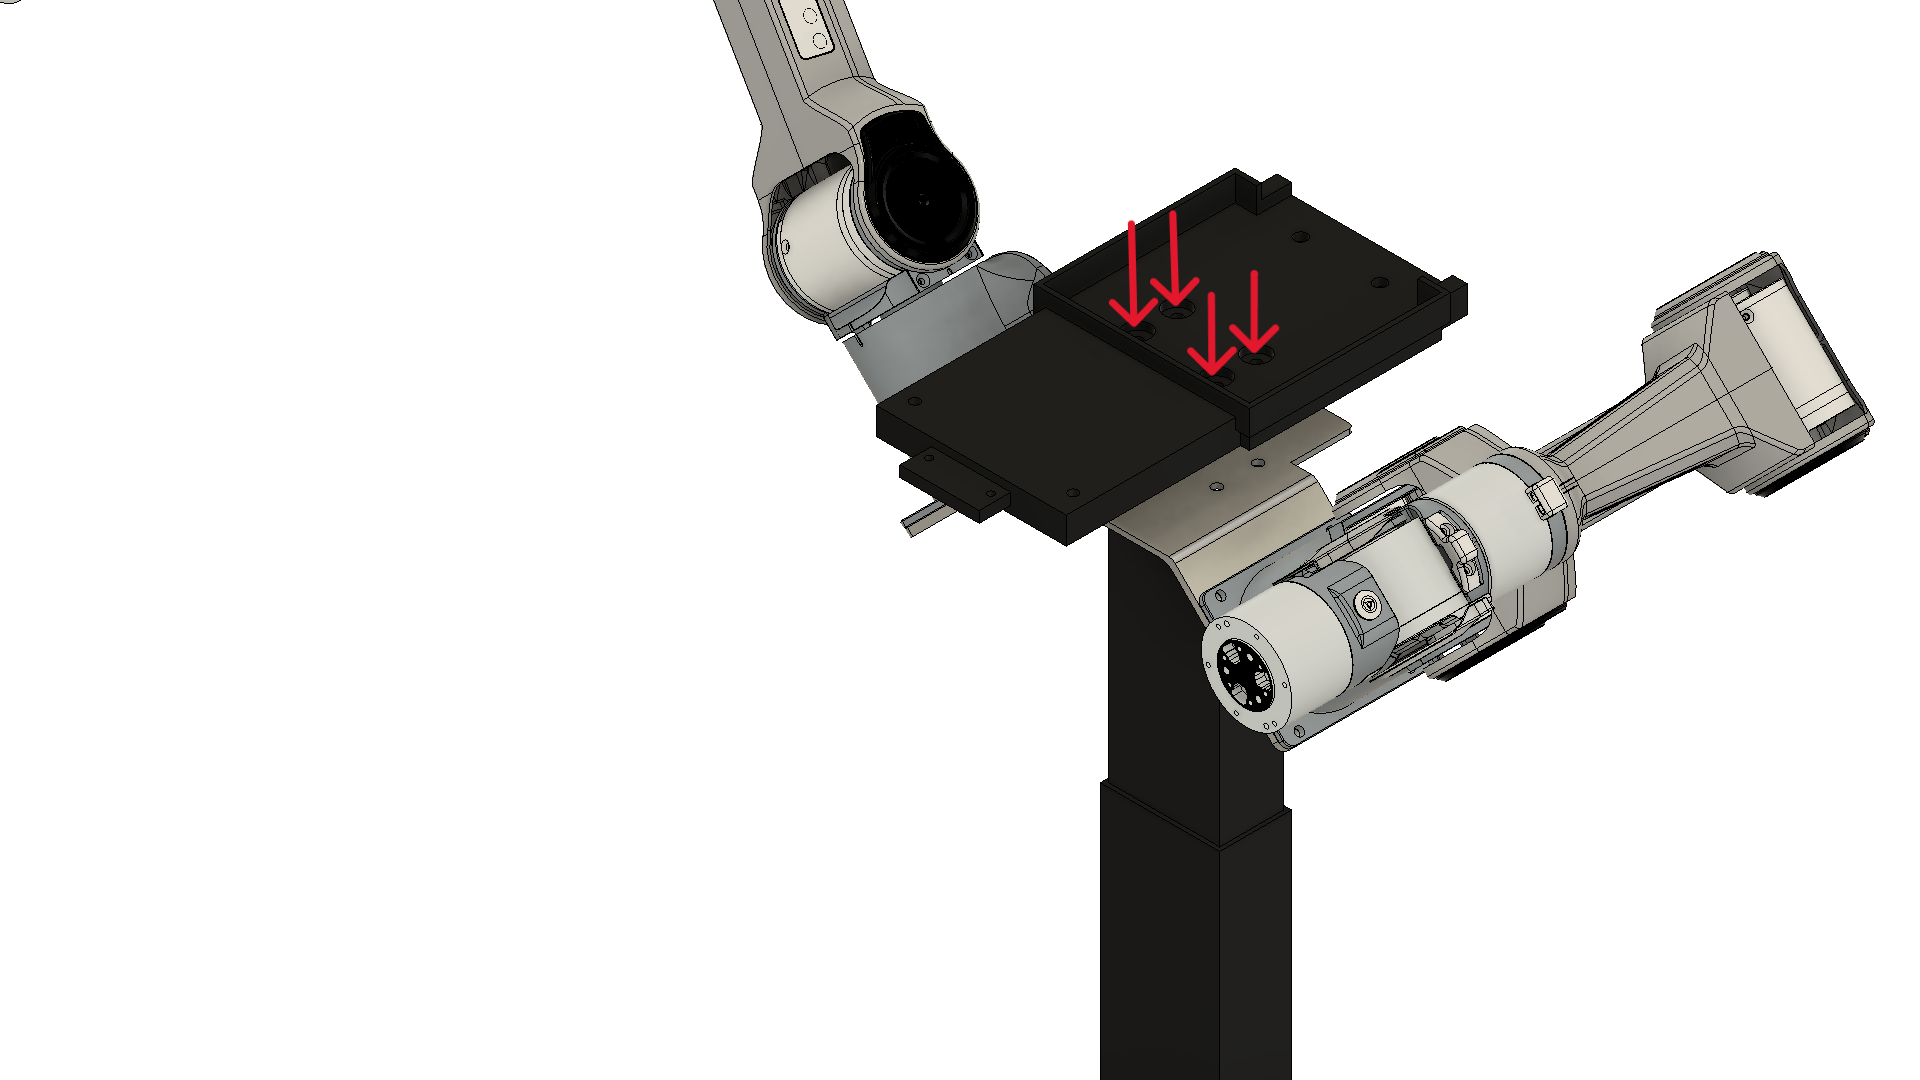
Now, we mount the arms to the lift using the four holes on the arm plate, we need the B screws that comes with the lift and M6 washers. Put the washer in and mount the arms plate using four B screws from the lift pack as shown in the figure.
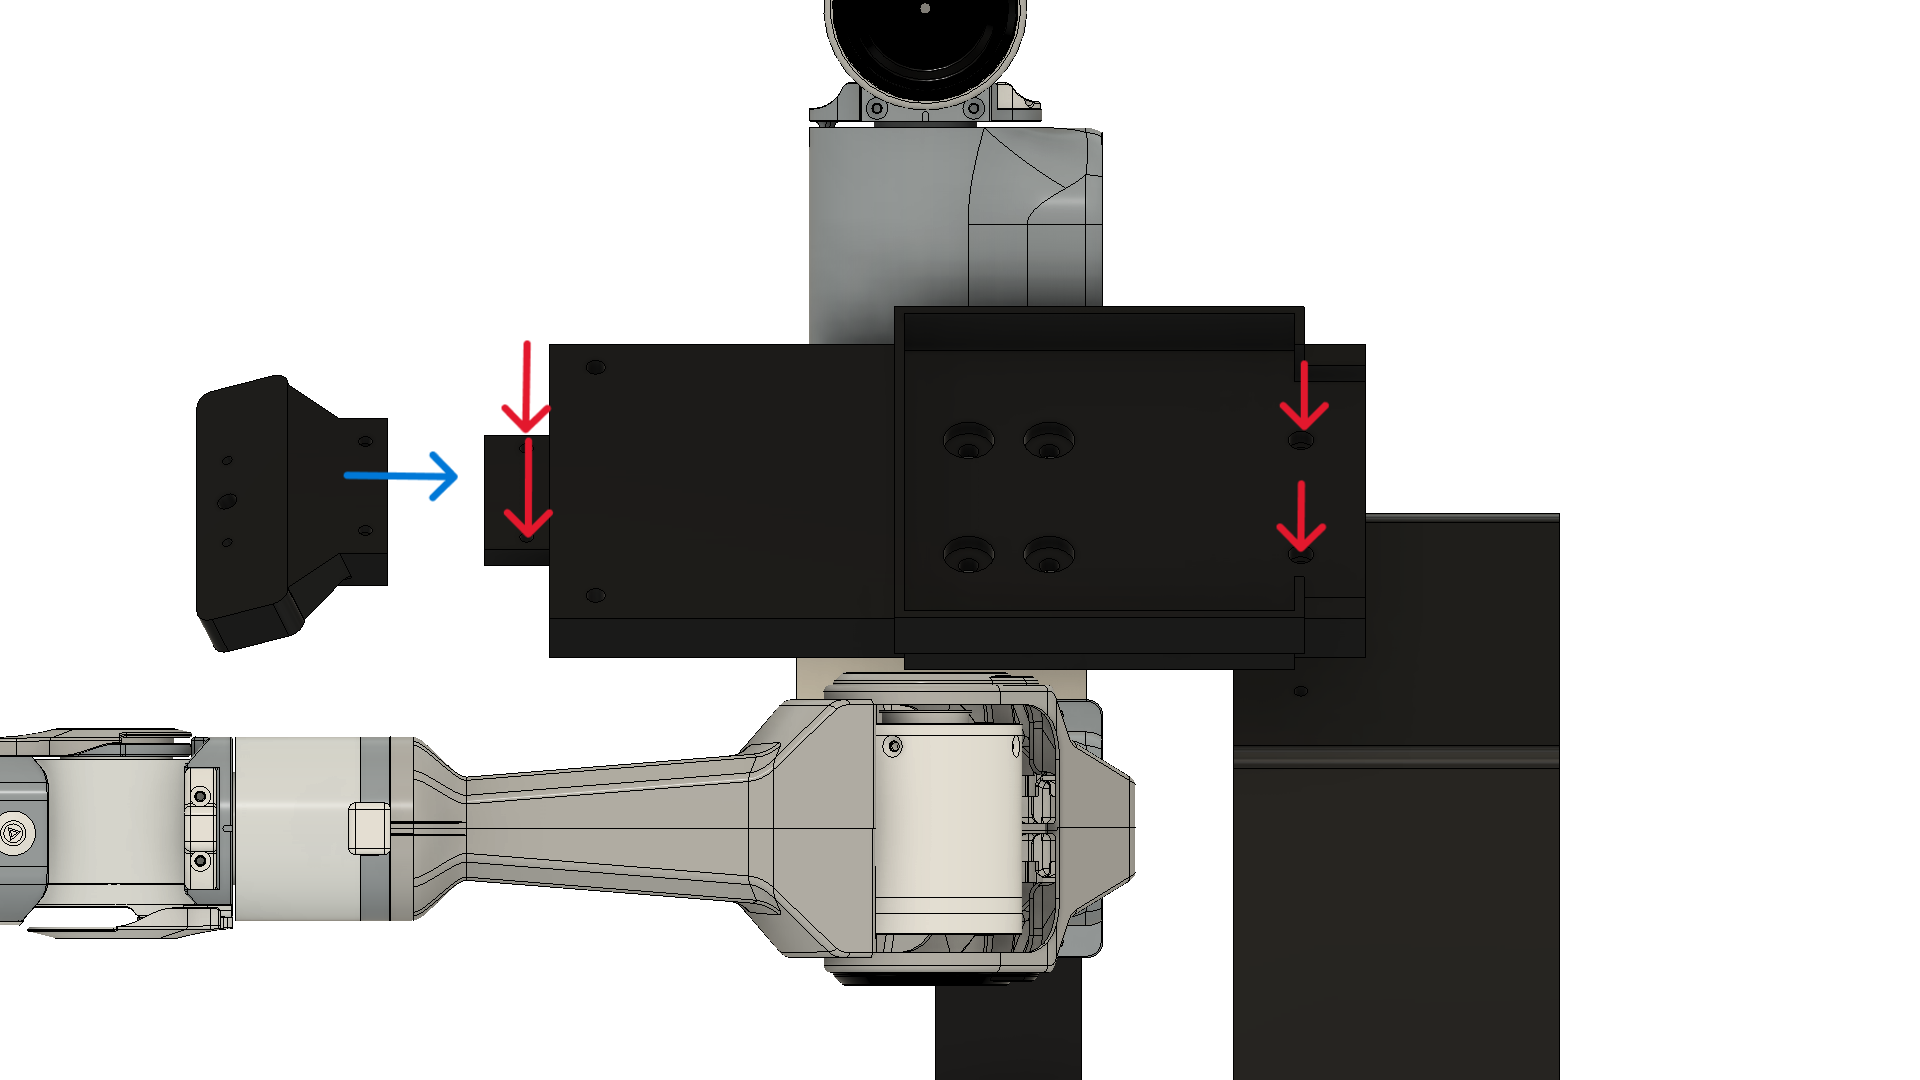
Now attach the ZED mount and the top cable tray using four M4 × 25 mm hex bolts and nuts. Slide the ZED mount into position as shown in the reference image, then secure it using two M4 hex bolts and nuts. Secure the top cable tray using the remaining two M4 × 25 mm hex bolts.
Now attach the ZED 2i and mount the Orin on top.
Once these steps are complete, YOR should match the configuration shown in the reference image.
Now we can attach the ZED 2i and mount the Orin on top.
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://build.yourownrobot.ai/5.-mounting-the-arms-1.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.